- World's first reasoning-centric, long-tail scenario open dataset designed to teach autonomous vehicles (AVs) human-like reasoning and decision making
- Motional launches nuReasoning Challenge at European Conference on Computer Vision for researchers and practitioners to advance next-generation driving foundation models
- Dataset and Challenge developed in partnership with the University of California Los Angeles (UCLA) Mobility Lab and its Director, Professor Jiaqi Ma
BOSTON, Sept. 8, 2026 /PRNewswire/ -- Motional, a leader in autonomous driving technology, announces the release of nuReasoning, the world's first reasoning-centric, long-tail scenario open dataset designed to teach autonomous vehicles (AVs) human-like reasoning and decision making. nuReasoning serves to advance the AV industry by training end-to-end autonomous systems with the common-sense intuition needed to navigate complex edge cases.
Today's most advanced artificial intelligence (AI) is moving beyond simply recognizing what it sees toward understanding the physical world, reasoning about what could happen next, and deciding how to act. Vision-Language-Action (VLA) models bring these capabilities together, but they need training data that teaches more than just the correct action, they also need to learn the logic behind that action. nuReasoning provides this missing supervision by teaching models to understand spatial relationships, reason about driving decisions, anticipate risks, and consider alternative outcomes.
Along with having 20,000 long-tail scenarios, nuReasoning provides unparalleled annotation. Each long-tail event, selected from Motional's millions of miles of driving data, has a video clip of at least 20 seconds that is embedded with high-quality and human verified reasoning. Through this annotation, researchers are able to understand not just what an AV perceives, but why specific actions were taken and why alternative choices were ruled unsafe.
A nuReasoning miniset release earlier this year has already been downloaded over 50,000 times, underscoring the need for a dataset of this kind within the advanced AI research community.
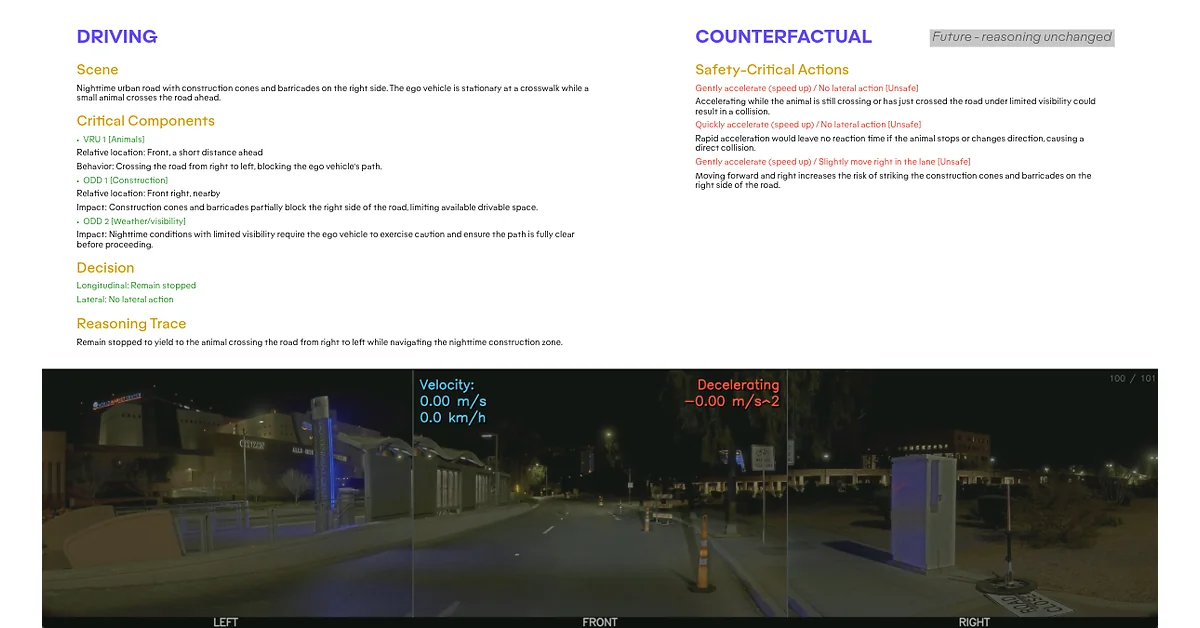
As shown above, one nuReasoning scenario features a nighttime construction zone and shows that the AV stopped before proceeding forward. The stop could be taken as the AV not understanding how to proceed through the zone. The scenario annotation details that the AV actually stopped correctly for a small animal crossing the road up ahead. Alternate routes were rejected because of construction barriers and the animal's unknown speed and direction.
"To safely expand AV fleets, autonomous driving systems must react to rare, chaotic edge cases with the same assured logic as an experienced human driver," said Phil Michel, Motional's Senior Vice President of Autonomy and AI. "At Motional, we're prioritizing transparent AI so we can clearly evaluate real-time decision-making and risk assessment. By making nuReasoning openly available, we're offering a shared foundation to help the entire industry solve edge cases and advance toward scalable autonomous operation."
To catalyze global research, Motional is hosting a nuReasoning Challenge, launching at the European Conference on Computer Vision (ECCV) in Sweden. The dataset and Challenge were created in partnership with the UCLA Mobility Lab and Professor Jiaqi Ma.
nuReasoning Dataset
Mined from real-world Motional fleet data across Las Vegas, Pittsburgh, Los Angeles, Boston, and Singapore, nuReasoning features:
- Over 105 hours of carefully selected reasoning intensive edge cases including unusual pedestrian activity, work zones and night road construction, animal crossings, and limited visibility scenarios.
- Diverse reasoning annotations support a broad range of VLA model training, including Spatial Reasoning, Decision Reasoning, and Counterfactual Reasoning.
- 247,000 reasoning annotations with human verified quality assurance.
- Multi-modal sensor types to provide complete scene representation in 3D space.
Additionally, Motional has integrated its proprietary Omnitag data search engine, giving nuReasoning researchers an intuitive navigation layer to query dataset distributions by scenario type, difficulty level, and location. Furthermore, Omnitag unlocks powerful natural language semantic search, allowing users to search complex tactical interactions, such as "emergency vehicle approaching behind with a construction site nearby " and instantly isolate matching data.
nuReasoning Challenge at European Conference on Computer Vision (ECCV)
Motional and the UCLA Mobility Lab are hosting the nuReasoning Challenge, launching at ECCV in Sweden.
The Challenge is designed as a joint evaluation of planning and reasoning on 1,000 private-test scenarios.
- Explainable Trajectory & Motion Planning: Benchmarking physical motion planning accuracy and safety compliance when guided by explicit counterfactual reasoning.
- Long-Tail Visual Question Answering & Scene Reasoning: Evaluating a model's ability to accurately infer spatial relationships, causal decision traces, and risk factors in edge cases.
Interested participants can find more information here. Submissions will be evaluated, and Challenge winners will be announced at the Conference on Neural Information Processing Systems (NeurIPS) in December.
Pioneering Open Safety Standards: From nuScenes to nuReasoning
nuReasoning extends Motional's legacy of advancing AV research through open data, beginning with nuScenes in 2019, the industry's first multi-modal public AV dataset, and continuing through nuImages, Panoptic nuScenes, and nuPlan. By providing open benchmarks, Motional empowers academic and commercial engineers to establish unified safety standards for AV perception, trajectory planning, and explainable AI.
Motional's datasets are available for commercial licensing or free academic use subject to Motional's non-commercial terms and conditions. Interested users can contact [email protected].
About Motional:
Motional is an autonomous vehicle technology company on a mission to make driverless vehicles a safe, reliable, and accessible reality. The company formed in 2020 and is majority-owned by Hyundai Motor Group, one of the world's largest vehicle manufacturers. Motional has extensive experience in commercial robotaxi operations, with service currently available on the Uber network in Las Vegas and plans for driverless operations by the end of 2026. Headquartered in Boston, Motional has operations in the U.S. and Singapore. For more information, visit www.Motional.com and follow the company on LinkedIn.
SOURCE Motional
Share this article